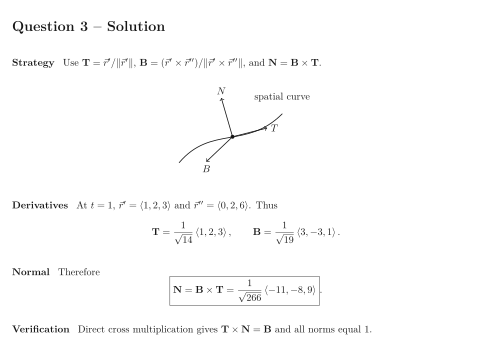
Question 3 Find the Frenet frame for r→(t)=⟨t,t2,t3⟩\vec r(t)=\left\langle t,t^2,t^3\right\rangle at t=1t=1. Use the cross-product method for 𝑩\mathbf B and verify the orientation. Show solutionHide solution+Question 3 – Solution Strategy Use 𝑻=r→′/∥r→′∥\mathbf T=\vec r'/\|\vec r'\|, 𝑩=(r→′×r→″)/∥r→′×r→″∥\mathbf B=(\vec r'\times\vec r'')/\|\vec r'\times\vec r''\|, and 𝑵=𝑩×𝑻\mathbf N=\mathbf B\times\mathbf T. See the diagram in the original worksheet below. Derivatives At t=1t=1, r→′=⟨1,2,3⟩\vec r'=\left\langle 1,2,3\right\rangle and r→″=⟨0,2,6⟩\vec r''=\left\langle 0,2,6\right\rangle. Thus 𝑻=114⟨1,2,3⟩,𝑩=119⟨3,−3,1⟩.\mathbf T=\frac 1{\sqrt{14}}\left\langle 1,2,3\right\rangle,\qquad \mathbf B=\frac 1{\sqrt{19}}\left\langle 3,-3,1\right\rangle. Normal Therefore 𝑵=𝑩×𝑻=1266⟨−11,−8,9⟩.\boxed{\mathbf N=\mathbf B\times\mathbf T=\frac 1{\sqrt{266}}\left\langle-11,-8,9\right\rangle}. Verification Direct cross multiplication gives 𝑻×𝑵=𝑩\mathbf T\times\mathbf N=\mathbf B and all norms equal 1.