Question 10
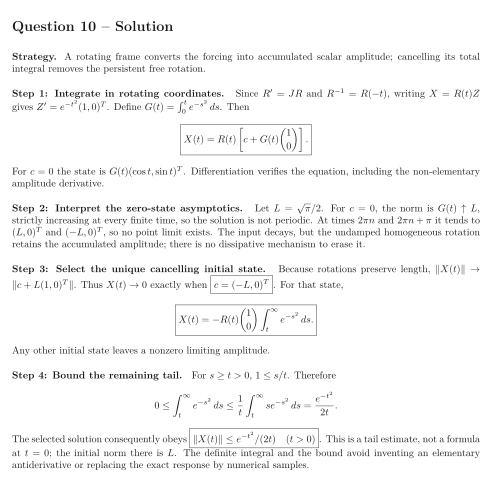
Let and . Consider You may use . Exact definite-integral answers are expected; no elementary antiderivative is assumed.
Tasks
Use variation of parameters to find the solution for arbitrary . Specialize to .
For , find the limiting norm. Does the state converge to a point or become periodic? Explain why forcing that tends to zero need not produce a state that tends to zero.
Find exactly the initial state that makes . Express that solution with an integral from to infinity.
Prove a quantitative decay bound for this selected solution using for , deriving the inequality as part of the solution.
Show solutionHide solution
Question 10 – Solution
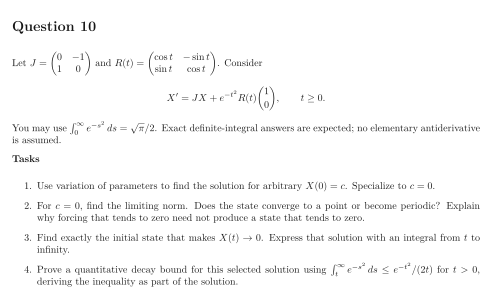
Strategy. A rotating frame converts the forcing into accumulated scalar amplitude; cancelling its total integral removes the persistent free rotation.
Step 1: Integrate in rotating coordinates. Since and , writing gives . Define . Then For the state is . Differentiation verifies the equation, including the non-elementary amplitude derivative.
Step 2: Interpret the zero-state asymptotics. Let . For , the norm is , strictly increasing at every finite time, so the solution is not periodic. At times and it tends to and , so no point limit exists. The input decays, but the undamped homogeneous rotation retains the accumulated amplitude; there is no dissipative mechanism to erase it.
Step 3: Select the unique cancelling initial state. Because rotations preserve length, . Thus exactly when . For that state, Any other initial state leaves a nonzero limiting amplitude.
Step 4: Bound the remaining tail. For , . Therefore The selected solution consequently obeys . This is a tail estimate, not a formula at ; the initial norm there is . The definite integral and the bound avoid inventing an elementary antiderivative or replacing the exact response by numerical samples.