Question 6
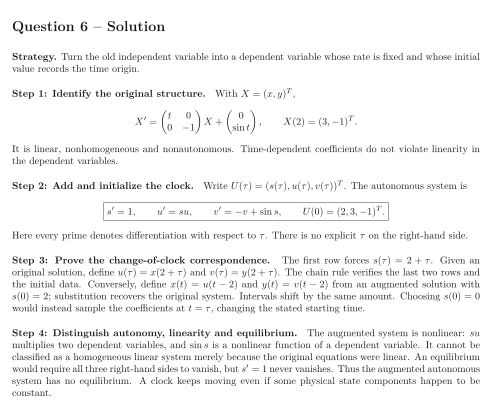
Consider the nonautonomous system A common way to remove explicit time is to add a clock as another state. In an autonomous system, the right-hand side depends only on the state.
Tasks
Write this as a two-dimensional linear system and classify homogeneity and autonomy.
Introduce a new independent variable and a clock satisfying . Give an autonomous three-dimensional system with initial data at that reproduces the stated IVP.
Prove the correspondence between solutions of the two systems, specifying exactly how and are related. Explain why the clock initial value is required.
Classify the augmented system as linear or nonlinear and find its equilibria. Explain why autonomous does not mean linear, and why adding a clock can eliminate all equilibria.
Show solutionHide solution
Question 6 – Solution
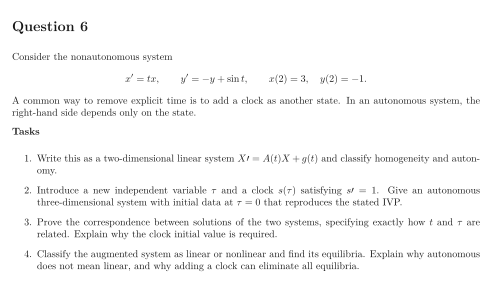
Strategy. Turn the old independent variable into a dependent variable whose rate is fixed and whose initial value records the time origin.
Step 1: Identify the original structure. With , It is linear, nonhomogeneous and nonautonomous. Time-dependent coefficients do not violate linearity in the dependent variables.
Step 2: Add and initialize the clock. Write . The autonomous system is Here every prime denotes differentiation with respect to . There is no explicit on the right-hand side.
Step 3: Prove the change-of-clock correspondence. The first row forces . Given an original solution, define and . The chain rule verifies the last two rows and the initial data. Conversely, define and from an augmented solution with ; substitution recovers the original system. Intervals shift by the same amount. Choosing would instead sample the coefficients at , changing the stated starting time.
Step 4: Distinguish autonomy, linearity and equilibrium. The augmented system is nonlinear: multiplies two dependent variables, and is a nonlinear function of a dependent variable. It cannot be classified as a homogeneous linear system merely because the original equations were linear. An equilibrium would require all three right-hand sides to vanish, but never vanishes. Thus the augmented autonomous system has no equilibrium. A clock keeps moving even if some physical state components happen to be constant.